Define the pick
Problem. Cup choice starts with the workpiece, not the catalogue.
What happens here. Workpiece material, surface condition, weight and orientation decide cup diameter, cup shape and rubber compound before anything else is chosen.
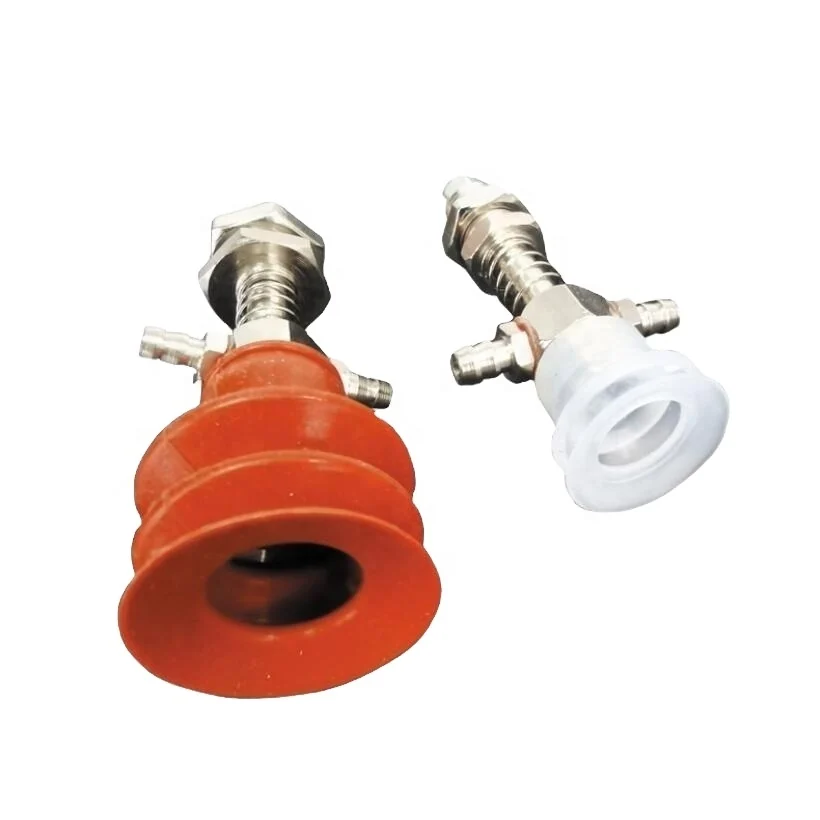
Building a vacuum gripper is a parts list, not a single purchase. Cups, holders, bars, clamps and fittings are quoted as one tool.
End of arm tooling is where a robot cell usually loses time. Cups are ordered without holders, thread sizes do not match, the tool comes out heavier than the payload, and the parts arrive in three separate shipments.
Problem. Cup choice starts with the workpiece, not the catalogue.
What happens here. Workpiece material, surface condition, weight and orientation decide cup diameter, cup shape and rubber compound before anything else is chosen.
Problem. Cup positions decide bar length, clamp count and total weight.
What happens here. Cup count and spacing are set against the part, then cross bars, clamps and swivel joints are selected to reach those positions with room to adjust.
Problem. A tool inside the payload figure can still overload the wrist through its centre of gravity offset.
What happens here. Tool weight and reach are added up so the load stays inside the robot rating with margin, and the layout is kept symmetrical.
Problem. Fittings and hose routing are usually left until assembly day.
What happens here. Fittings, hose sizes and spring compensator stroke are specified with the mechanical parts so the tool can be piped as it is built.
Problem. Separate line items from separate suppliers arrive at different times.
What happens here. Cups, holders, bars, clamps and fittings are quoted on one sheet and shipped together from Zhuhai.
Problem. Cups harden, leak and start dropping parts.
What happens here. The cup specification stays on file, so a repeat set is quoted from the previous order number rather than re-specified from scratch.
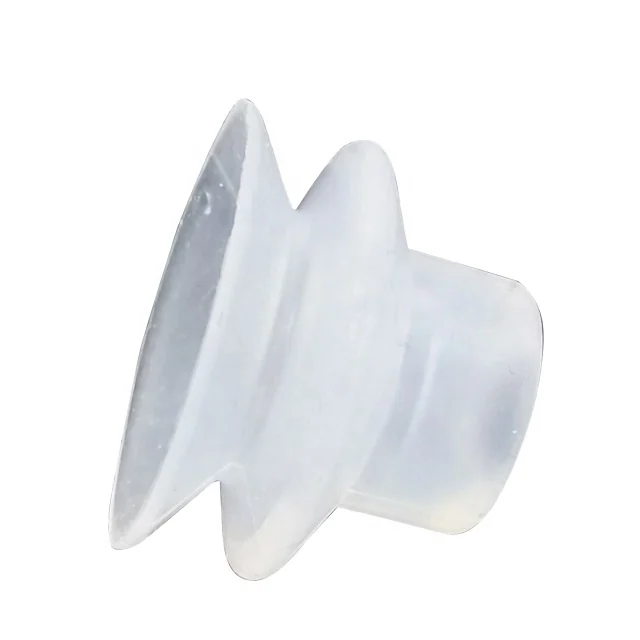
Mrright supplies vacuum rubber suckers for robot end-of-arm tooling and pick-and-place heads, used to lift sheet, board, film, glass, and packaging materials. Stock is held in Zhuhai and shipped worldwide on inquiry.
Mrright supplies robot holders and sucker mounting arms as pre-assembled kits from stock in Zhuhai. These aluminium and steel components fix suction cups, grippers and sensors to robot arms or gantry beams.
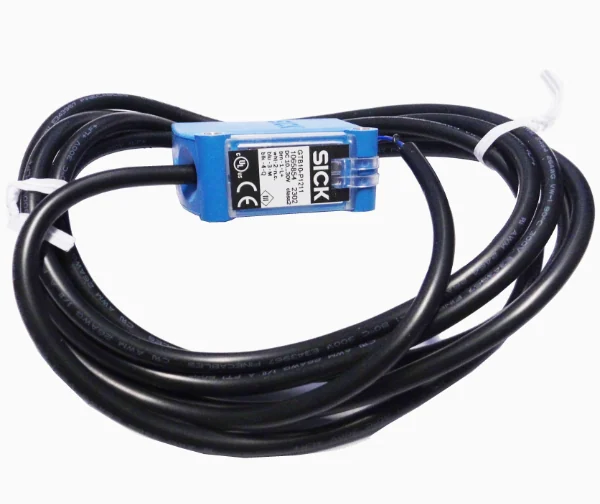
Mrright supplies industrial sensors for machine automation including inductive and capacitive proximity switches, photoelectric sensors, fibre amplifiers, magnetic cylinder switches, and pressure switches. Multi-brand stock is held in Zhuhai and shipped worldwide on inquiry.
Yes. Cups, holders, cross bars, clamps and vacuum fittings are quoted together as one parts list and shipped in one box.
Oil resistant compounds such as NBR are the usual choice for oily surfaces. Send the sheet thickness, weight and surface condition and the compound and cup size are proposed with the quotation.
No. Mrright supplies the tooling parts, the suction cups, holders and fittings, and the automation components around them.
It depends on part weight, orientation and acceleration, and cups are normally split across the part to control tilt. Send the part drawing or dimensions and a cup count is proposed.
Yes, and most buyers reorder in sets because cups are consumables that wear at a similar rate.
Send the photo or the list. The first reply tells you what is in stock and what is not.